Four 128×64 OLEDs, each independently programmable. Feather ESP32-S3 with WiFi, NTP, battery gauge, and a 3D-printed enclosure.
Personal projects and engineering work: embedded hardware, robotics, and software tools.
Four 128×64 OLEDs, each independently programmable. Feather ESP32-S3 with WiFi, NTP, battery gauge, and a 3D-printed enclosure.
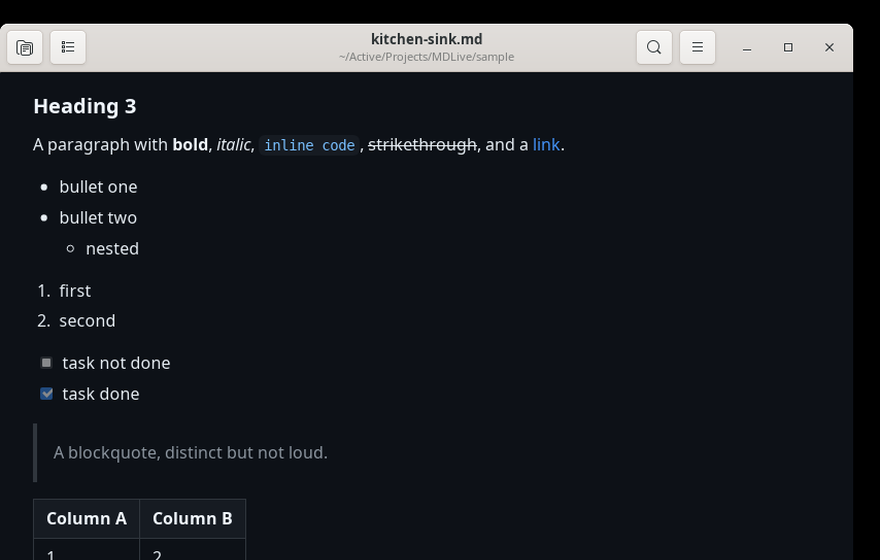
A Markdown previewer that re-renders the moment the file changes on disk. Native macOS app (Swift, WKWebView) plus a Linux port (GTK3, WebKit2GTK) sharing the same renderer.
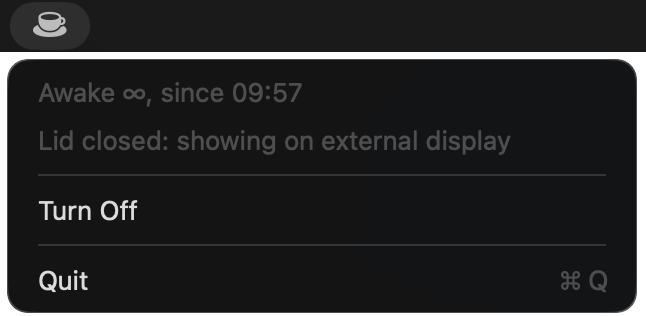
Keep a Mac fully awake from the terminal or a menu bar item: no sleep, no display sleep, no screensaver, no auto-lock, with sensible lid and external display handling.
Starting the Master of Science in Information at UMSI in Winter 2027 through the UCAD pathway.
This is my last semester of the robotics engineering undergrad at the College of Engineering; I graduate in December 2026. Along the way I've led and worked on multi-person robotics and human-robot interaction projects: real-time experimental systems, Python automation tools, and software-to-hardware integrations.
This past summer I built full-stack web apps at Decypher, from the database and API up to the UI, using AI-assisted, spec-first tools. Most of my work was shipping data integrations, product features, and internal tools that took ideas to something people actually used.
Built LabVIEW control software for a LIN-based water pump testbench, supported warranty analysis, and worked with engineering and sales teams on thermal-management products.
Ran BLDC motor validation on DYNO systems, updated test procedures, and produced training materials that standardized internal workflows.
I'm a robotics engineering student at the University of Michigan who builds interactive systems: real-time software, embedded hardware, and the interfaces people use to work with them. I care about taking a project from concept to something deployed, with clean architecture and a front end that feels fast and considered.